Tommaso Belvedere
Research Scientist @ Rainbow Team, INRIA
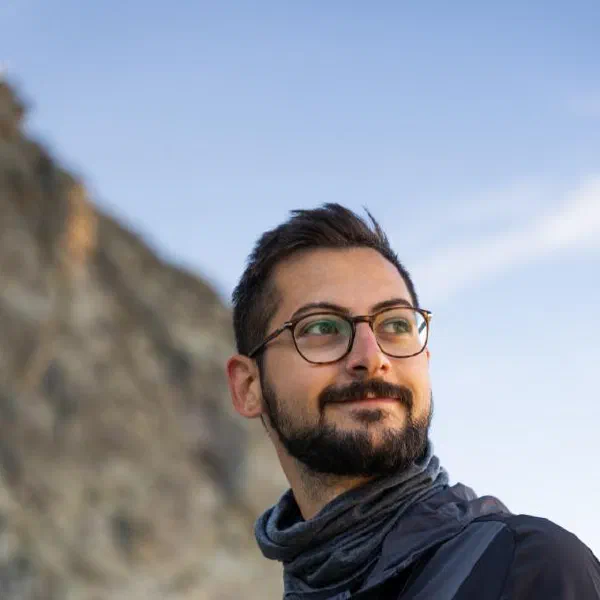
From October 2026, I am a tenured Research Scientist (Chargé de Recherche) within the Rainbow Team at INRIA in Rennes, France. My research focuses on developing methodologies to make robots move efficiently, safely, and robustly, with particular emphasis on optimization-based methods such as Model Predictive Control. My work spans multiple robotic platforms including wheeled, legged, and aerial robots. Currently, I am mainly interested in tackling the problem of robustifying robot actions against model uncertainties, and in the combination of heterogeneous control methods (optimization, learning, etc…) towards more modular robotics systems.
Before, from June 2024, I was a CNRS PostDoc researcher within the same team, working with Dr. Paolo Robuffo Giordano.
In 2025 I have been a Visiting Researcher at the DRAGON Lab of the University of Tokyo in collaboration with Prof. Moju Zhao.
I was previously a PhD student at the DIAG Robotics Lab, where I worked under the supervision of Prof. Giuseppe Oriolo on the the development of Model Predictive Control strategies for non-minimum phase systems including articulated vehicles, wheeled balancing robots, and humanoid robots.
I serve as an Associate Editor for robotics conferences, including ICRA {2025, 2026, 2027} and IROS 2025, and for the IEEE Robotics and Automation Letters (RA-L).
In the past, I’ve helped in the organization of JNRR 2025 at INRIA Rennes, of an ICRA 2025 Workshop “Beyond the Lab: Robust Planning and Control in Real World Scenarios”, and a workshop on “Recent Advancements in Aerial Manipulation” held at INRIA Rennes
news
| Jul 1, 2026 | I gave a talk at UCL during the Proactive Robotics Workshop. |
|---|---|
| May 11, 2026 | Our T-RO paper “Sensitivity-Aware Model Predictive Control for Robots with Parametric Uncertainty” won the Best Paper Award of the IEEE RAS TC on Optimization for Robotics. |
| Jan 1, 2026 | I have been appointed as Associate Editor for IEEE Robotics and Automation Letters (RA-L). |
| Aug 4, 2025 | Currently visiting the DRAGON Lab at the University of Tokyo. |
| May 23, 2025 | Organized the workshop “Beyond the Lab: Robust Planning and Control in Real World Scenarios” at ICRA 2025 in Atlanta. |
selected publications
- From pixels to touch: Direct tactile servoing with learned photometric normalizationIEEE Robotics and Automation Letters, 2026
@article{priorsancho2026pixels, title = {From pixels to touch: Direct tactile servoing with learned photometric normalization}, author = {Prior Sancho, Lluis and Belvedere, Tommaso and Tognon, Marco}, journal = {IEEE Robotics and Automation Letters}, volume = {11}, number = {6}, pages = {7142--7149}, year = {2026}, issn = {2377-3766}, doi = {10.1109/LRA.2026.3685944}, } - Feedback-MPPI: Fast Sampling-Based MPC via Rollout Differentiation – Adios Low-Level ControllersIEEE Robotics and Automation Letters, 2026
@article{belvedere2026feedbackmppi, title = {Feedback-MPPI: Fast Sampling-Based MPC via Rollout Differentiation -- Adios Low-Level Controllers}, author = {Belvedere, Tommaso and Ziegltrum, Michael and Turrisi, Giulio and Modugno, Valerio}, journal = {IEEE Robotics and Automation Letters}, volume = {11}, number = {1}, pages = {1--8}, year = {2026}, doi = {10.1109/LRA.2025.3630871}, } - Sensitivity-Aware Model Predictive Control for Robots with Parametric UncertaintyIEEE Transactions on Robotics, 2025Winner of the Best Paper Award of the IEEE RAS Technical Committee on Optimization for Robotics, 2026.
@article{belvedere2025sensitivity,
  title   = {Sensitivity-Aware Model Predictive Control for Robots with Parametric Uncertainty},
  author  = {Belvedere, Tommaso and Cognetti, Marco and Oriolo, Giuseppe and Robuffo Giordano, Paolo},
  journal = {IEEE Transactions on Robotics},
  volume  = {41},
  pages   = {3039--3058},
  year    = {2025},
  doi     = {10.1109/TRO.2025.3554415},
}